Fabio Slika Stella

Embedded Linux · Firmware · Motor control

Fabio Slika Stella

Senior Embedded Linux & Firmware Engineer

I ship firmware and Embedded Linux on production devices (electronic security, railway, automotive): Yocto, Device Tree, Linux kernel drivers and bare-metal C/C++ on ARM Cortex-M. Currently Systems Developer II at Control iD.

Pato Branco, PR, Brazil · Portuguese (native) · English (advanced) · CV em português

01

About

Computer Engineer (UTFPR) working end to end on embedded products: production Embedded Linux images with Yocto/BitBake, Device Tree (DTS/DTB) and Linux kernel drivers/BSP, and bare-metal Embedded C/C++ on ARM Cortex-M (MSP, STM32, ESP32): bootloaders, OTA, cryptography, MQTT, Ethernet/TCP-IP, CAN, RS-485, I²C and UART.

My background spans electronic security, railway and automotive. My research roots are in motor control: Field-Oriented Control of BLDC/PMSM motors and Extended Kalman Filter state estimation, which I keep exploring in open-source firmware and inverter hardware.

I work in cross-functional teams, listen closely, and treat code review as engineering, not conflict.

How I work

  • Understand the system before optimizing it
  • Measure before guessing
  • Read the datasheet
  • Respect physics
  • Automate everything repeatable
  • Keep firmware boring and reliable
02

Experience

  1. 2026 — Present

    Systems Developer II · Control iD

    São Paulo, Brazil · Access-control devices

    • Owned production Embedded Linux images (Yocto/BitBake, Device Tree DTS/DTB, Linux kernel drivers) for access-control devices.
    • Developed bare-metal Embedded C/C++ on 3 ARM Cortex-M families (MSP, STM32, ESP32): bootloader, OTA and board bring-up.
    • Integrated cryptography, Ethernet, TCP/IP, MQTT and web services; led code review and GDB debug on the R&D team.

    YoctoDevice TreeKernel driversMSP · STM32 · ESP32OTA

  2. 2024

    Embedded Systems Engineer · Progress Rail (Caterpillar)

    Railway · Locomotive controllers

    • Shipped locomotive-controller firmware in C/C++ with CAN, RS-485 and 4G Ethernet via cellular modem (MSP).
    • Designed data architecture, persistent storage and microcontroller memory map for field operation.

    C/C++CANRS-4854GMSP

  3. 2024

    Software Engineer · Zeentech / Stellantis

    Automotive

    • Built MATLAB/Simulink vehicle models and validated automotive embedded code from simulation to bench.

    MATLAB/SimulinkModel-based validation

  4. 2022 — 2024

    Embedded Systems Developer · InoBram

    Industrial products

    • Wrote STM32 bare-metal firmware in C across a 2-year industrial product cycle, including bootloader, OTA and bring-up.

    STM32Bare-metal CBootloaderOTA

  5. 2022

    Test Engineer · IAV do Brasil

    Automotive electronics

    • Performed white-box HIL validation of automotive electronics with Typhoon HIL.

    HILTyphoon HIL

  6. 2021 — 2022

    R&D Intern · Xpert Automação

    R&D

    • Implemented ESP32/STM32 bare-metal firmware; deployed OpenWrt on a commercial router adopted as the product network backbone.

    ESP32STM32OpenWrt

Education

B.S. Computer Engineering · UTFPR

Universidade Tecnológica Federal do Paraná · 2014 — 2022

FOC research 2020 — 2022. Dissertation: Simulation of an Extended Kalman Filter for Brushless DC Motor (advisor: Emerson G. Carati).

Publication & courses

Study of a Brushless DC Motor with Extended Kalman Filter

2021

Course: Bare-Metal STM32 (Udemy, 2023).

03

Featured projects

Open-source work on GitHub, mostly around power measurement and motor control. Status is stated as it is in each repository.

InstrumentationWorking

power_profiller

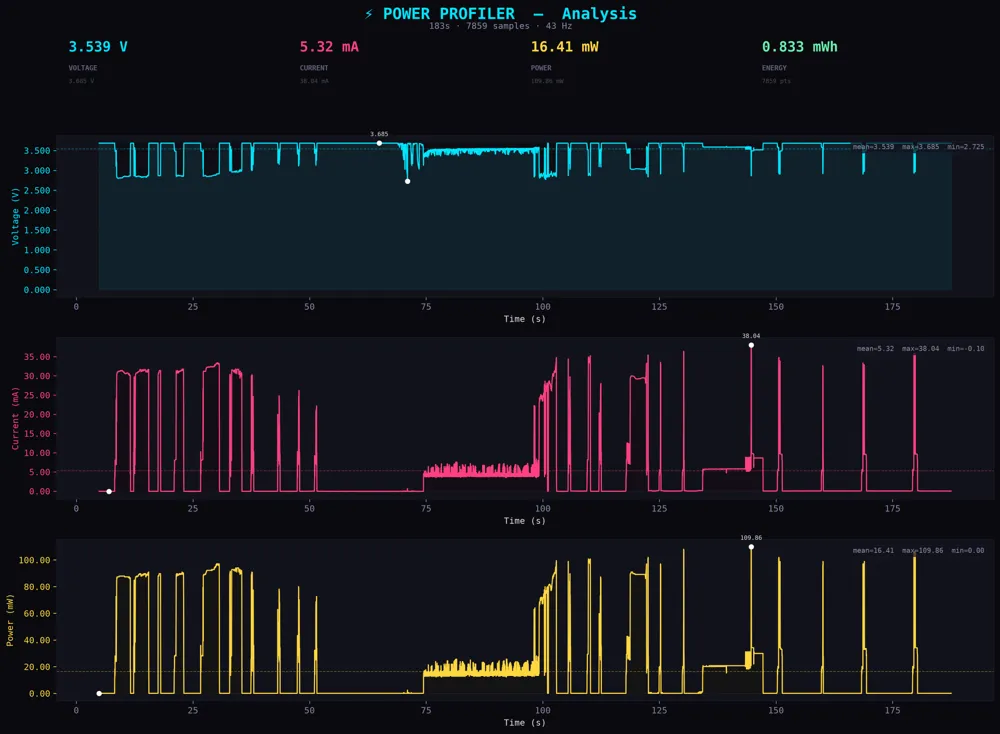
Real-time energy profiling for battery-powered electronics. An ESP32 reads a TI INA226 over I²C at ~36 samples/s, streams CSV over serial and serves a live Chart.js dashboard over Wi-Fi with no cloud. A Python analyzer adds burst detection and CR2032 battery-life estimates.

CESP-IDFFreeRTOSINA226 · I²CPython
Motor control firmwareWork in progress

ESP32-FOC

ESP32 firmware toward Field-Oriented Control of a BLDC motor. Today it runs open-loop V/F control: a potentiometer on the ADC sets the speed reference, a FreeRTOS task integrates the electrical angle, and MCPWM drives three half-bridges at 1 kHz.

CESP-IDFMCPWMBLDC

Power electronicsStudy

3-phase-inverter

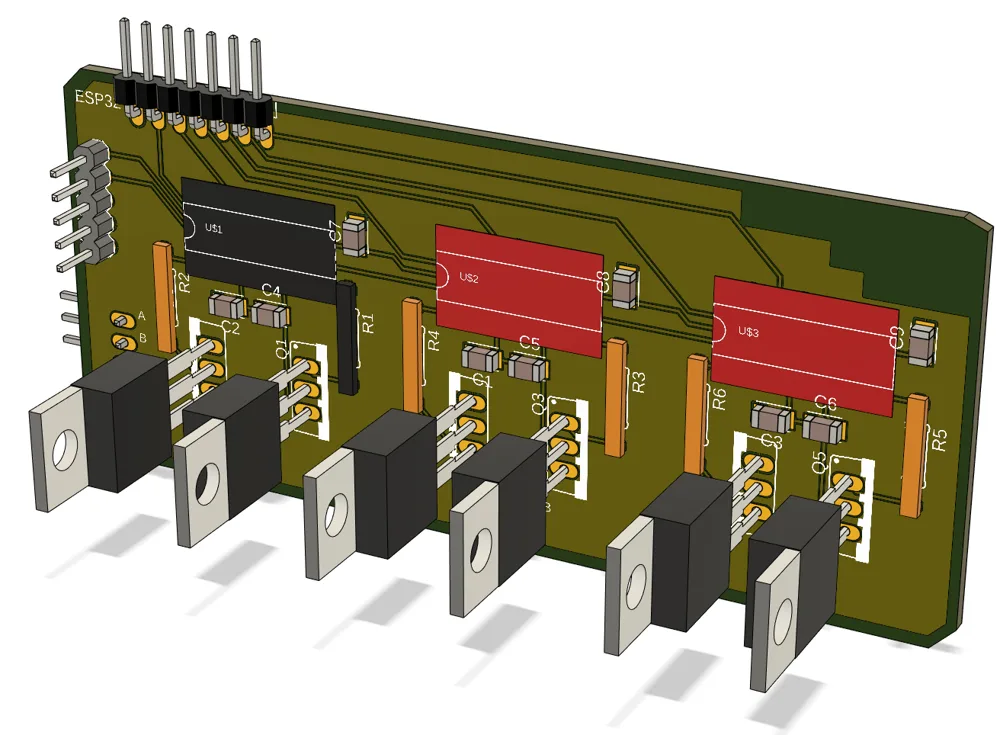
Six-switch inverter for BLDC motors: three IR2110 gate drivers and six IRF540N MOSFETs (VDD 5 V, VCC 15 V), documented with PCB renders and datasheet notes. It is the power stage for ESP32-FOC.

IR2110IRF540NPCBGPL-3.0

Traction inverter · PMSMPhase 0 · modeling

OTPC · Open Traction PMSM Controller

An open-source FOC platform aimed at electric-motorcycle traction drives, built simulation-first. The repository has the PMSM model with Clarke/Park transforms and dq dynamics in Python, plus a written theory doc. STM32 firmware and the power stage are planned.

FOCPMSMPythonSTM32 (planned)

More on GitHub

04

Skills

Embedded Linux

Yocto ProjectBitBakeOpenEmbeddedDevice TreeDTS / DTBLinux kernelKernel driversBSPOpenWrtGCC

Firmware

Bare-metalBootloaderOTABoard bring-upARM Cortex-MSTM32ESP32MSP

Connectivity & security

CANRS-485I²CUARTEthernetTCP/IPMQTT4GCryptography

Languages & tools

CC++Embedded CPythonMATLABBashAssemblyGDBGitCMakeMATLAB/SimulinkTyphoon HIL

05

Contact

Happy to talk about Embedded Linux, firmware and motor-control work.

fabioslikastella@gmail.com